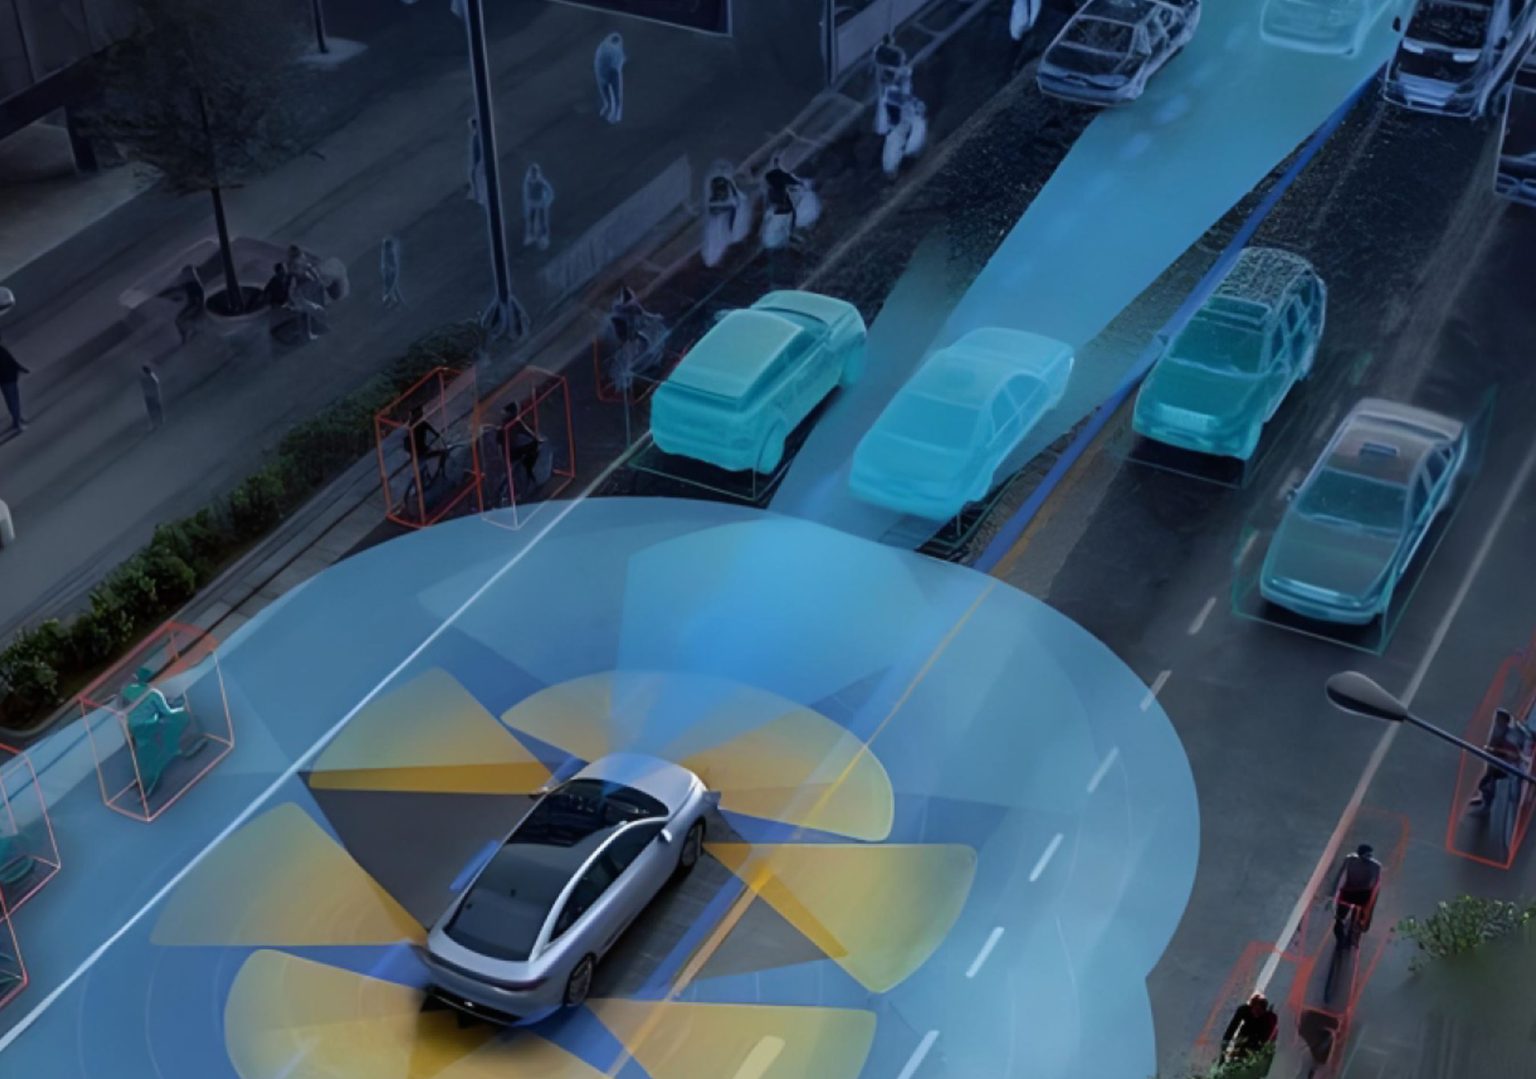
The problem on the ground
When a vehicle’s Extended Kalman Filter starts arguing with its GPS, it ain’t a small nuisance — it’s a safety problem. Out in practice, GNSS spoofing and RF interference can push position fixes off-course, and multipath only makes the filter less sure. That’s where a good anti-jamming GNSS antenna becomes part of the sensor stack, because you can’t rely on raw satellite data when the signal-to-noise ratio is tanking.
Why EKF and antenna hardware gotta play nice
EKF algorithms fuse IMU, wheel odometry, lidar or camera cues with GNSS. If the GNSS input is biased by jamming or falls into a multipath pit, the filter will drift or overtrust bad data. Higher antenna gain and selective filtering from a phased array or null steering system reduce contaminated measurements before they hit the EKF. In short: clean up the RF first, then tune the math.
Field steps for tuning EKF with anti-jam systems
Start with baseline logging: collect GNSS raw observables, IMU gyro/accel, and fix quality metrics over representative drives. Next, set measurement covariance adaptively — raise GNSS covariance when SNR drops or when fix quality flags spike. If you’ve got an active anti jam antenna, route its quality telemetry into the estimator so the EKF knows when to lean on IMU or vision. Practical sequence:
– Log and timestamp every sensor stream together.
– Implement an SNR threshold tied to GNSS weight in the EKF.
– Test transitions in low-signal areas, then verify recovery once the antenna regains clean locks.
Common missteps engineers keep making
Too many teams hard-code GNSS trust or ignore antenna modes. That makes EKFs yank the state when jamming starts. Another trap is neglecting system latency: anti jam antenna processing and a phased array’s beamforming introduce delays that must be accounted for in the state update. Finally, skipping on-site validation is a rookie move — lab tests don’t always show local RF anomalies. Trust the drive tests over simulations every time.
Real-world lesson and anchor
Remember the documented GPS jamming incidents reported for vessels in the Black Sea region? Operators saw sudden position jumps that ruined automated navigation profiles; crews who paired resilient antenna systems with conservative EKF covariances recovered far faster. That example shows hardware and filter work together, not separately — the antenna keeps bad inputs from poisoning the estimator, and the EKF adapts when inputs degrade.
Tuning checklist and troubleshooting tips
Follow this quick checklist during integration. First, verify antenna nulls and beam patterns in the field. Second, map SNR and fix-quality to covariance scaling. Third, implement fallback loops that promote IMU/odometry when GNSS confidence is low. If you run into repeated bias after a jam, recalibrate alignment between IMU and antenna; small misalignments breed long-term drift — and they’re easy to miss.
Three critical metrics to evaluate success
Measure these and you’ll know whether your stack’s shipshape: 1) Position divergence after a simulated jam (meters over time), 2) Recovery time to nominal RMSE once clean GNSS returns, and 3) Percentage of time the EKF relies on non-GNSS sensors during contested periods. Those metrics give you objective ways to compare antenna options and filter strategies, especially when choosing between simple choke rings and full null-steering arrays like an advanced anti jam antenna.
Small tweak, big difference.
Use those metrics. Measure recovery, not just uptime. Calibrate often. Archimedes Innovation.